Growing the forest…

Rafsan Isdani

Open to Opportunities

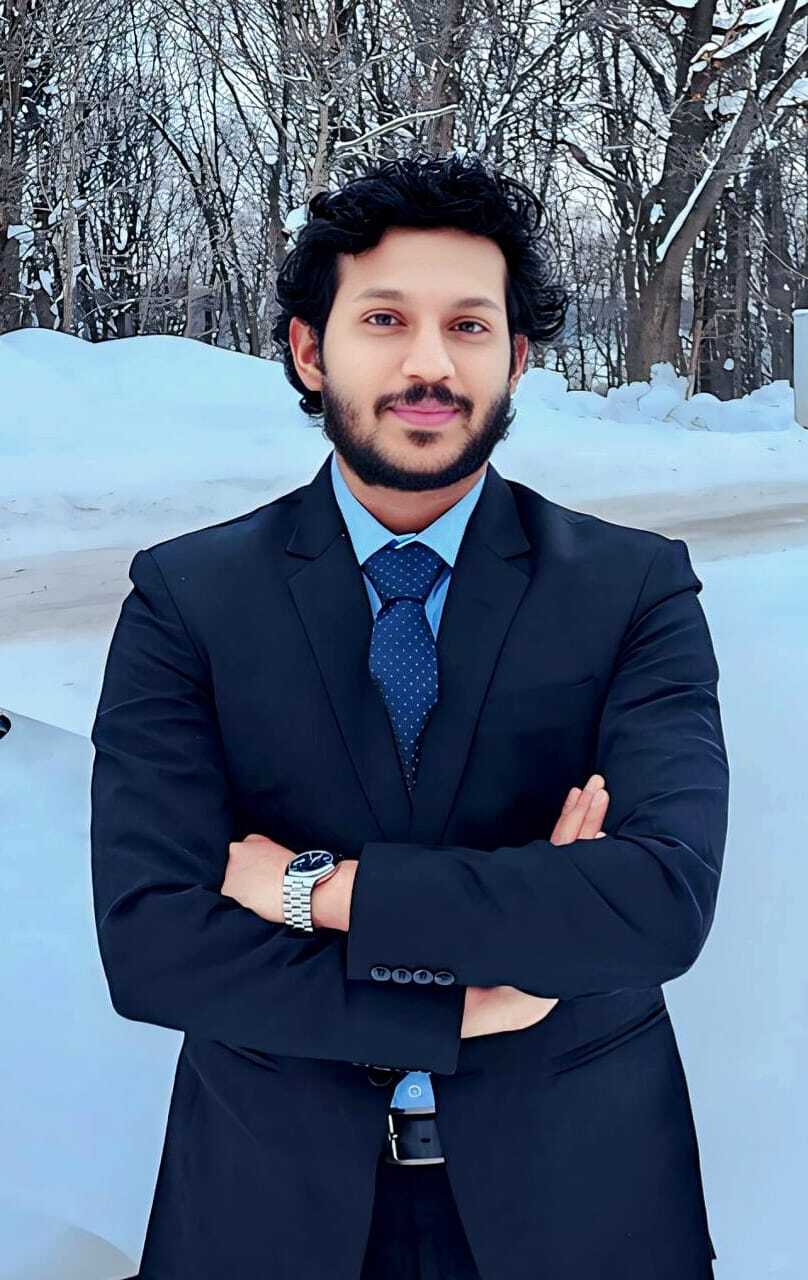
Md Rafsan Isdani

Mechatronics, Robotics & Automation Engineer

  • MS · Michigan Technological University
  • B.Tech · Marwadi University, India

Scroll to see the map

    Md Rafsan Isdani

    About

    About Me

    Mechatronics, Robotics & Automation Engineer · MS, Michigan Technological University

    I'm a Mechatronics, Robotics & Automation Engineer with a Master of Science from Michigan Technological University and a Bachelor of Technology in Automobile Engineering from Marwadi University, India.

    My expertise lies in PLC programming, SCADA system design, industrial robotics (FANUC), and real-time control — bridging mechanical systems with intelligent automation to build solutions that work on the factory floor.

    Beyond engineering, I carry leadership values from serving as a Cadet Sergeant in BNCC and as Youth Chief of Bangladesh Red Crescent, experiences that shaped my discipline, teamwork, and commitment to community.

    I'm currently expanding into AI-enabled industrial inspection as a Volunteer Research Assistant in the Department of Applied Computing, applying computer vision and deep learning to automated defect detection and predictive maintenance for Industry 4.0 manufacturing systems.

    Away from the lab, I write literary fiction as Rafsan Isdani — four novels so far, all listed under Books & Writing.

    • MSMechatronics
      Michigan Tech
    • B.TechAutomobile Eng.
      Marwadi University
    • 8+Engineering
      Projects
    • GTAPhysics Dept.
      Michigan Tech

    Journey

    My Journey

    1. 2024 – 2026

      M.S. Mechatronics, Robotics & Automation

      Michigan Technological University, Houghton, MI

      Focus on Industrial Automation, Robotics, and Real-time Control systems.

      Key Courses: Advanced PLC, Real-time Robotics (FANUC), Data Acquisition & Signal Processing, Control Systems, Dynamics & Kinematics.

    2. Jul 2026 – Present

      Volunteer Research Assistant — Applied Computing

      Michigan Technological University

      Conducting literature reviews and technical documentation on AI-enabled industrial inspection, computer vision, and smart manufacturing systems. Analyzing camera image datasets and evaluating machine vision techniques for automated defect detection and quality inspection.

      Focus: Designing and developing AI-based inspection solutions for Industry 4.0 manufacturing applications.

    3. Aug 2025 – May 2026

      Graduate Teaching Assistant — Physics

      Michigan Technological University

      Instructed undergraduate physics labs, guiding over 250+ students across 2 independent engineering physics lab courses in experimental methods, instrumentation, data acquisition, and technical problem-solving.

      Applied mechatronics and engineering principles to bridge theory with real-world engineering systems, evaluating performance and managing grades using Canvas and the university database.

    4. 2019 – 2023

      B.Tech Automobile Engineering

      Marwadi University, Rajkot, Gujarat, India

      Built a strong foundation in mechanical systems, thermodynamics, automotive design, manufacturing processes, and vehicle dynamics. Developed hands-on skills through projects and lab work in automotive engineering.

    5. Jan 2021 – Dec 2021

      Technical Intern — Office of International Affairs

      Marwadi University, Rajkot, India

      Administered and maintained student records using web-based information systems and Microsoft Excel. Ensured data accuracy, consistency, and system reliability through formulas, data validation, and reporting.

    6. Leadership & Discipline

      Cadet Sergeant — BNCC

      Bangladesh National Cadet Corps

      Served as Cadet Sergeant in the Bangladesh National Cadet Corps (BNCC), developing strong leadership, discipline, and teamwork skills through rigorous military-style training, drills, and community service activities.

    7. 2017

      Youth Chief — Bangladesh Red Crescent Society

      Chittagong Port College Unit

      Led the youth division of Bangladesh Red Crescent Society at Chittagong Port College, organizing humanitarian aid activities, disaster relief awareness, first aid training, and community health campaigns.

    Skills

    Technical Skills

    Industrial Automation

    • RSLogix 5000 (Allen-Bradley)
    • TIA Portal (Siemens S7-1500/1200)
    • SCADA (Ignition)
    • HMI (FactoryTalk)
    • Ladder Logic Programming
    • Structured Text (ST)

    Robotics

    • FANUC (TP / ROBOGUIDE)
    • ROS / Gazebo / Rviz
    • SLAM & Navigation

    Programming

    • Python
    • MATLAB / Simulink
    • C
    • LabVIEW

    Design & Simulation

    • SolidWorks
    • AutoCAD
    • Fusion 360
    • MATLAB
    • Gazebo
    • Rviz
    • SLAM
    • LabVIEW
    • Linux
    • ROBOGUIDE

    AI/ML & Computer Vision

    • Machine Learning
    • Deep Learning (PyTorch)
    • Computer Vision
    • Predictive Maintenance

    Projects

    Projects

    HPC · HPT C-MAPSS 21 sensors · 707 engines SENSOR PLOTS VLM OBSERVER Qwen2.5-VL-7B · trend · band · abstain 8 RUL MODELS XGBoost · BiLSTM · TCN · Transformer DETERMINISTIC FUSION FIGURE LEGIBILITY Unreadable figures FD001 FD003 FD002 FD004 1 regime vs 6 regimes 3 seeds · 4 subsets 2,121 VLM queries Bounded ±15% reweight Wilcoxon + paired t-test Abstention as signal VLM Evidence for Turbofan RUL Prognostics NASA C-MAPSS · Vision-Language + Numerical Fusion
    Research · Michigan Tech

    VLM-Assisted Prognostics — Turbofan RUL on NASA C-MAPSS

    • Vision-Language Models
    • Deep Learning
    • PHM

    Built a two-branch prognostic framework that pairs eight numerical remaining-useful-life (RUL) models (XGBoost, BiLSTM, TCN, MS-TCN, Transformer and more) with Qwen2.5-VL-7B, which reads full-history plots of all 21 engine sensors and reports degradation trend, regime, a qualitative life band and figure legibility — or abstains when a plot is unreadable. A deterministic, bounded fusion rule keeps the final RUL under numerical control.

    Evaluated on all four C-MAPSS subsets (707 test engines) across three random seeds. Visual evidence did not improve RUL accuracy, but it exposed a strong reliability signal: the VLM judged 13–20% of figures unreadable under a single operating condition versus 58–60% under six — pointing to VLMs as a qualitative screening and evidence-quality layer rather than a numerical predictor.

    Status: Submitted for publication — Aerospace Science and Technology (Elsevier).

    • Python
    • PyTorch
    • Qwen2.5-VL
    • XGBoost
    • Transformers
    • Predictive Maintenance
    View Code on GitHub
    LIGHT CURTAIN PNEU 218 mm min. safety distance ISO 13849-1 CH 1 CH 2 CAT 3 / PLd E-STOP PFHd: 2.47×10⁻⁷/h DCavg / MTTFd: OK Response: ≤100 ms SIL 2 compliant Next: PLe / SIL 3 valve monitoring Project Neptune — Pneumatic Cobot Workcell Safety
    Michigan Tech

    Project Neptune — Pneumatic Cobot Workcell Safety Assessment

    • ISO 13849-1
    • Functional Safety
    • Risk Assessment

    Conducted an ISO 13849-1 safety assessment of a pneumatic collaborative robot workcell featuring a Category 3 dual-channel safety architecture. Calculated MTTFd, DCavg, and PFHd (2.47 × 10⁻⁷/h) to verify compliance with Performance Level d (PLd) and SIL 2 requirements.

    Determined a minimum safety distance of 218 mm with a total system response time of ≤100 ms per ISO 13855, and proposed downstream pressure monitoring and automated valve testing to support future PLe/SIL 3 compliance.

    • ISO 13849-1
    • ISO 13855
    • Functional Safety
    • Machine Safety
    • Industrial Automation
    LIGHT SENSOR Vernier NI PCI-6024E DAQ Interface 2ms sampling 28BYJ-48 Stepper Motor LabVIEW — Position Control GUI RPM CW / CCW FULL / HALF STEP Lux trend MATLAB / Simulink Light In Speed Ctrl NI ELVIS III Live RPM + Lux Dashboard Data Acquisition — Real-Time Stepper Motor Control
    Michigan Tech

    Data Acquisition & Real-Time Motor Control System

    • LabVIEW
    • MATLAB/Simulink
    • NI DAQ

    Designed a LabVIEW-based position control system integrating a Vernier light sensor with a 28BYJ-48 stepper motor to achieve real-time bidirectional rotation control based on object proximity, with 2 ms sensor sampling, direction control, and selectable full/half-step operation through a custom GUI.

    Developed a MATLAB/Simulink speed control model to regulate motor speed based on ambient light intensity via an NI PCI-6024E DAQ interface, with a live dashboard for monitoring RPM and light intensity (Lux) trends in real time.

    • LabVIEW
    • MATLAB/Simulink
    • NI ELVIS III
    • NI PCI-6024E DAQ
    • Sensor Integration
    BASE θ₁ R1 R2 R3 P (slide) AOI CAM PART 8 INSPECTION WAYPOINTS PD CONTROLLER Error Kp d(err)/dt Kd Kp = Kd = 5 + Gravity/Coriolis Simulation: 14 s Collision-free tracking Minimal tracking error 4-DOF RRRP Manipulator — AOI Trajectory Simulation SolidWorks + MATLAB Simscape Multibody
    Michigan Tech

    4-DOF RRRP AOI Robotic Manipulator

    • SolidWorks
    • Simscape Multibody
    • Control Systems

    Designed and simulated a 4-DOF RRRP robotic manipulator for Automated Optical Inspection (AOI) using SolidWorks, MATLAB Simulink, and Simscape Multibody. Developed inverse kinematics and smooth 3D trajectory planning across 8 inspection waypoints using polynomial interpolation and homogeneous transformation matrices.

    Implemented a PD controller (Kp = Kd = 5) with gravity and Coriolis compensation for accurate, stable trajectory tracking — achieving collision-free motion with minimal tracking error throughout a 14-second simulation.

    • SolidWorks
    • MATLAB
    • Simulink
    • Simscape Multibody
    • Inverse Kinematics
    • Trajectory Planning
    ALLEN-BRADLEY PLC Controller 33% 50% 66% IGNITION SCADA TEMP MONITORING COOLING Al 6061 | Nylon 101 AUTOMATED DUTY CYCLE PLC → SCADA → COOLING CONTROL LOOP Allen-Bradley + Ignition SCADA Integration
    Michigan Tech

    Dynamic Temperature Cooling — Allen-Bradley PLC

    • PLC
    • SCADA
    • Ladder Logic

    Engineered and programmed an Allen-Bradley CompactLogix PLC-based forced convection cooling system using Ladder Logic with programmable duty-cycle profiles (33%, 50%, and 66%) for autonomous thermal process control. Developed an Ignition SCADA HMI for real-time monitoring and validated cooling performance on Aluminum 6061 and Nylon 101.

    Status: Research publication under review — Materials & Design (Elsevier).

    • Allen-Bradley PLC
    • Ignition SCADA
    • RSLogix 5000
    • Ladder Logic
    • FactoryTalk HMI
    FANUC BASE EOAT GRIP WRAP ROBOGUIDE Simulation & Verification TP Programming FANUC EOAT — Automated Grip Wrapping
    Michigan Tech

    FANUC Robot EOAT Automation

    • FANUC
    • ROBOGUIDE
    • TP Programming

    Designed, 3D printed, and assembled a vacuum-based end-of-arm tool (EOAT) in SolidWorks for automated tennis racket overgrip application using a FANUC robot. Integrated relay-controlled DC motor circuitry and pneumatics, then programmed synchronized robot motion with TP programming and verified the workflow in ROBOGUIDE. Evaluated 20+ test configurations, achieving consistent, defect-free overgrip application at 5V motor input and 80 mm/s robot speed.

    • FANUC Robot
    • TP Programming
    • ROBOGUIDE
    • EOAT Design
    • Motion Planning
    ROBOT ROS STACK /slam_node /nav_stack /lidar_driver /wall_follower /sensor_fusion Gazebo Simulation Environment Mobile Robot — ROS SLAM Navigation
    Michigan Tech

    Mobile Robot Navigation — ROS & SLAM

    • ROS
    • SLAM
    • Gazebo

    Programmed multi-sensor mobile robots for wall-following and autonomous mapping using ROS and SLAM algorithms in a Gazebo simulation environment. Implemented sensor fusion for reliable real-time navigation, and validated performance by generating environment maps and demonstrating reliable path-following on real-world hardware.

    • ROS
    • SLAM
    • Gazebo
    • Python
    • Sensor Fusion
    US1 US2 BLIND SPOT ARDUINO UNO WARNING SYSTEM Distance Detection: 2.5m detected Alert Levels: Safe (>3m) Caution (1-3m) Danger (<1m) Audible + Visual Alert Anti-Collision Warning — Arduino + Ultrasonic
    Marwadi Univ.

    Anti-Collision Warning System

    • Arduino
    • Sensors
    • C

    Developed an ultrasonic sensor and Arduino-based system to reduce blind spot risks in heavy vehicles. Real-time distance detection triggers audible and visual warnings for drivers, enhancing road safety.

    • Arduino
    • Ultrasonic Sensors
    • C Programming
    • Embedded Systems
    • PCB Design

    Founder

    Antiproton Technologies

    Engineering Intelligence into Machines — software for robotics, intelligent systems and simulation. Two products are out on the Microsoft Store, both free and fully offline.

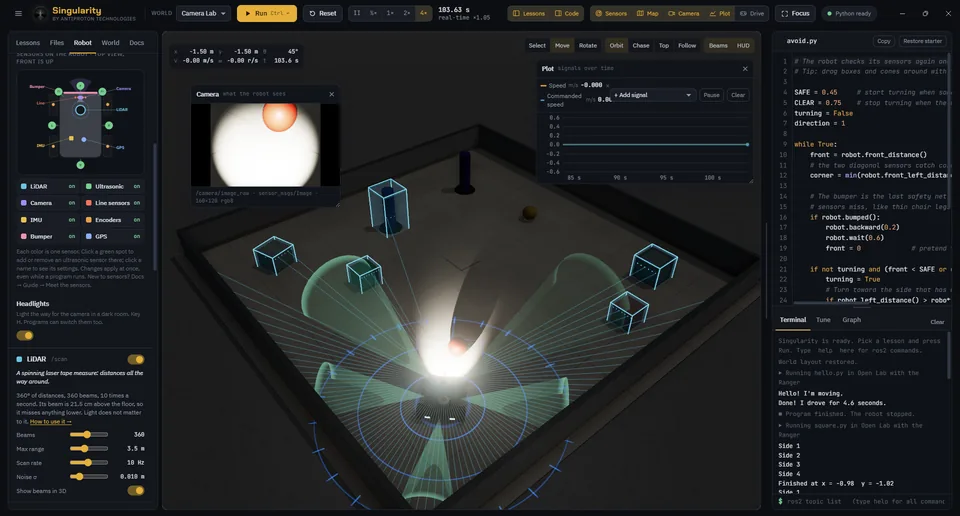
    Singularity running the Camera Lab world: a robot with LiDAR beams and ultrasonic cones, a live camera window, and a Python program in the editor.
    Released · v1.0

    Singularity

    • Robotics simulator
    • Python
    • Free

    A robotics learning simulator for Windows. Program a robot in Python and watch it sense, think and move in real-time 3D — from simple commands to ROS-style nodes.

    • Virtual LiDAR, ultrasonic, camera, IR, IMU, encoders and GPS
    • 16 guided lessons, from first moves to SLAM
    • 8 ready-made worlds, plus a world builder
    • Works fully offline — no accounts, no tracking
    • Python 3.12
    • NumPy
    • 3D physics
    • ROS 2 / ROS 1 style
    • Windows 10 / 11
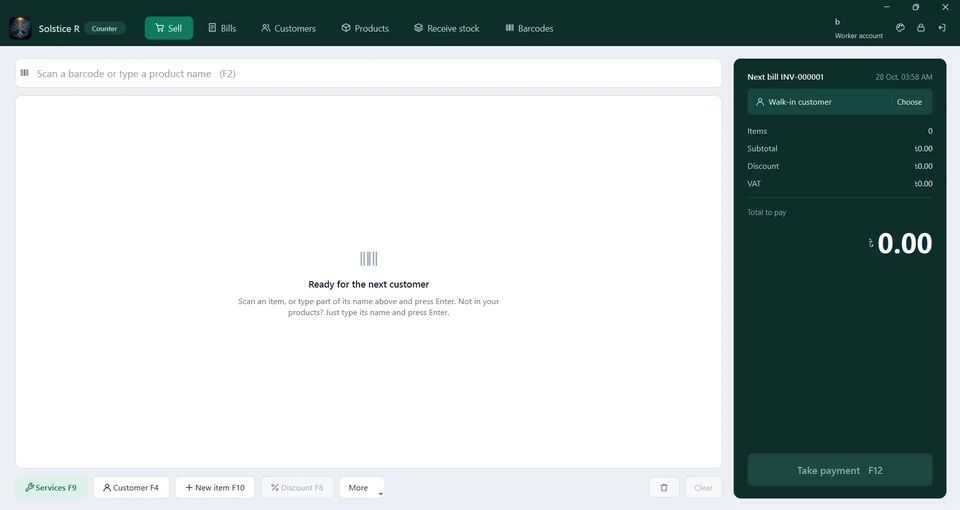
    Solstice R counter screen: a large scan box, the bill ready for the next customer, and the totals panel with Take payment.
    Released · v0.9.2

    Solstice R

    • Billing & inventory
    • Point of sale
    • Free

    Billing, stock and sales for shops — fast at the counter, clear for the owner. Built for small businesses that want a reliable till without a subscription or the internet.

    • Scan or type, add services, split payments and credit
    • Thermal receipts, A4 invoices, PDF and barcode labels
    • Owner and worker accounts; bills can be corrected with history kept
    • Several counters on one shop network, with daily backups
    • Python
    • Qt (PySide6)
    • SQLite
    • Encrypted shop network
    • Windows 10 / 11

    Fiction · Rafsan Isdani

    Books & Writing

    Stories drawn to quieter things — people, places, memory, love, and what remains after something has ended.

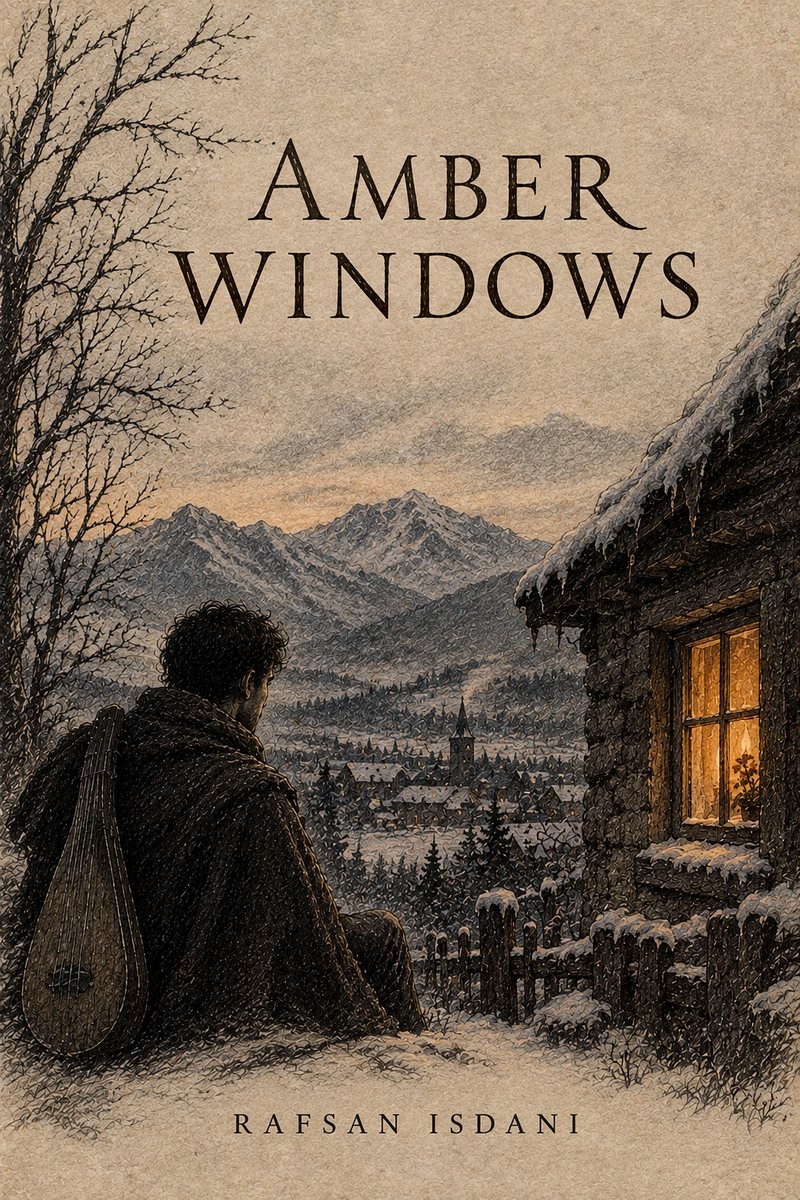
    Cover of Amber Windows by Rafsan Isdani

    No. 01 · First Novel

    Amber Windows

    A wintry literary novel of longing and belonging — of lit windows seen from the cold, and the people we keep carrying long after we leave them.

    Literary Fiction · Hardcover & Kindle · 2026

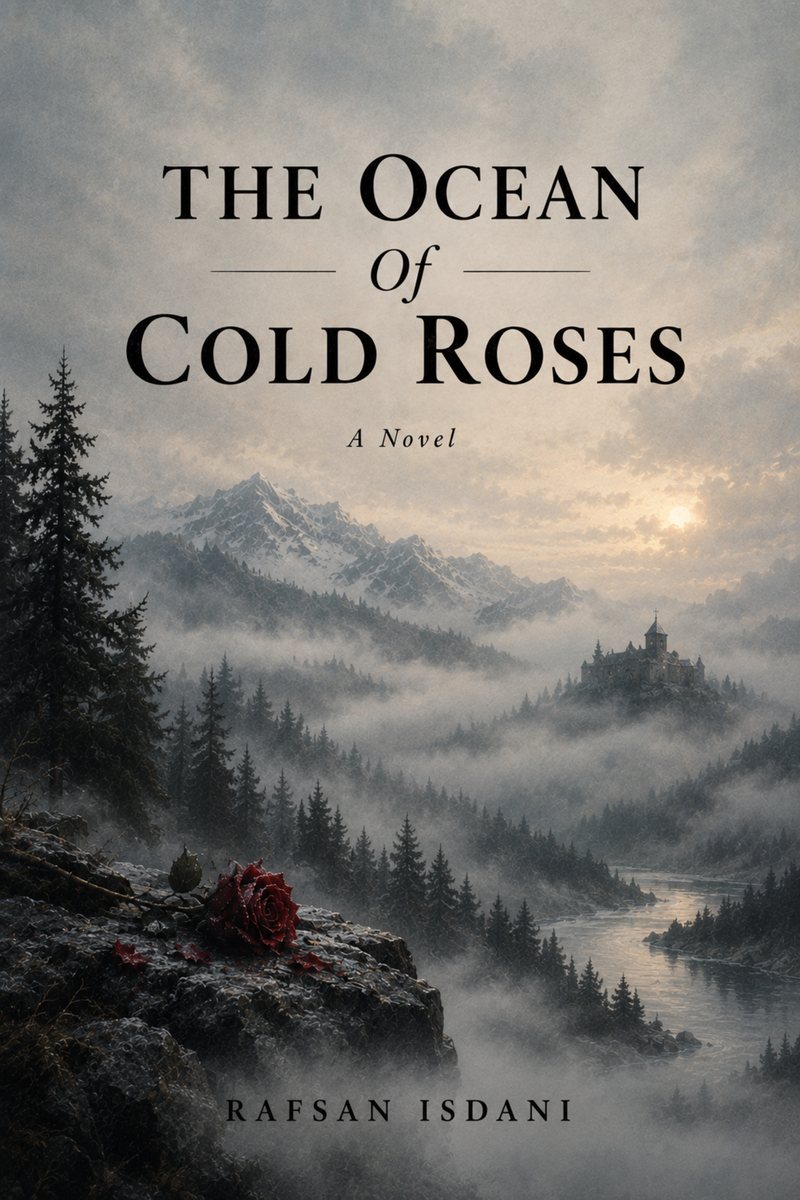
    Cover of The Ocean of Cold Roses by Rafsan Isdani

    No. 02 · Second Novel

    The Ocean of Cold Roses

    A literary novel of love and memory, set among mist, mountains and still water — about the feelings that are hardest to name.

    Literary Fiction · Hardcover & Kindle · 2026

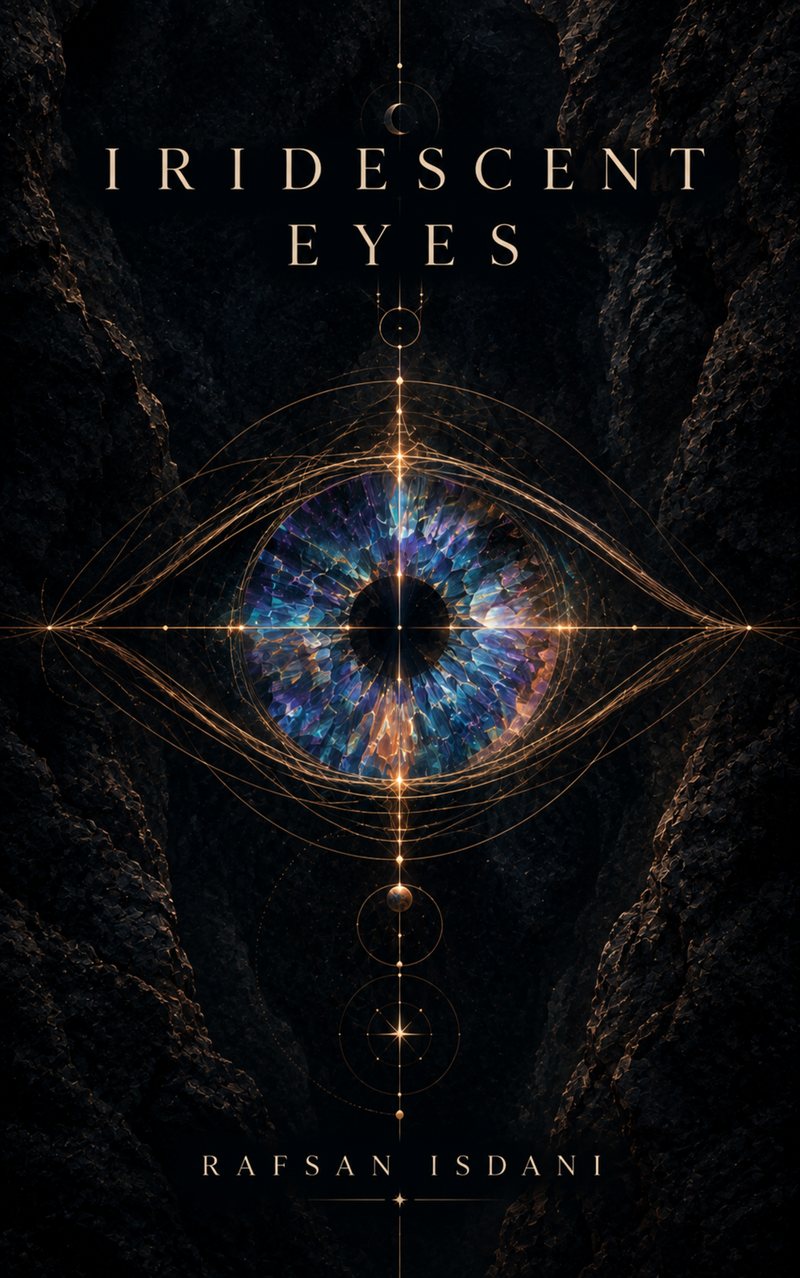
    Cover of Iridescent Eyes by Rafsan Isdani

    No. 03 · Third Novel

    Iridescent Eyes

    Literary science fiction set in Kharun, a settlement in the canyons — Aren's story of seeing, and of what a world chooses not to see.

    Literary Sci-Fi · Hardcover & Kindle · 2026

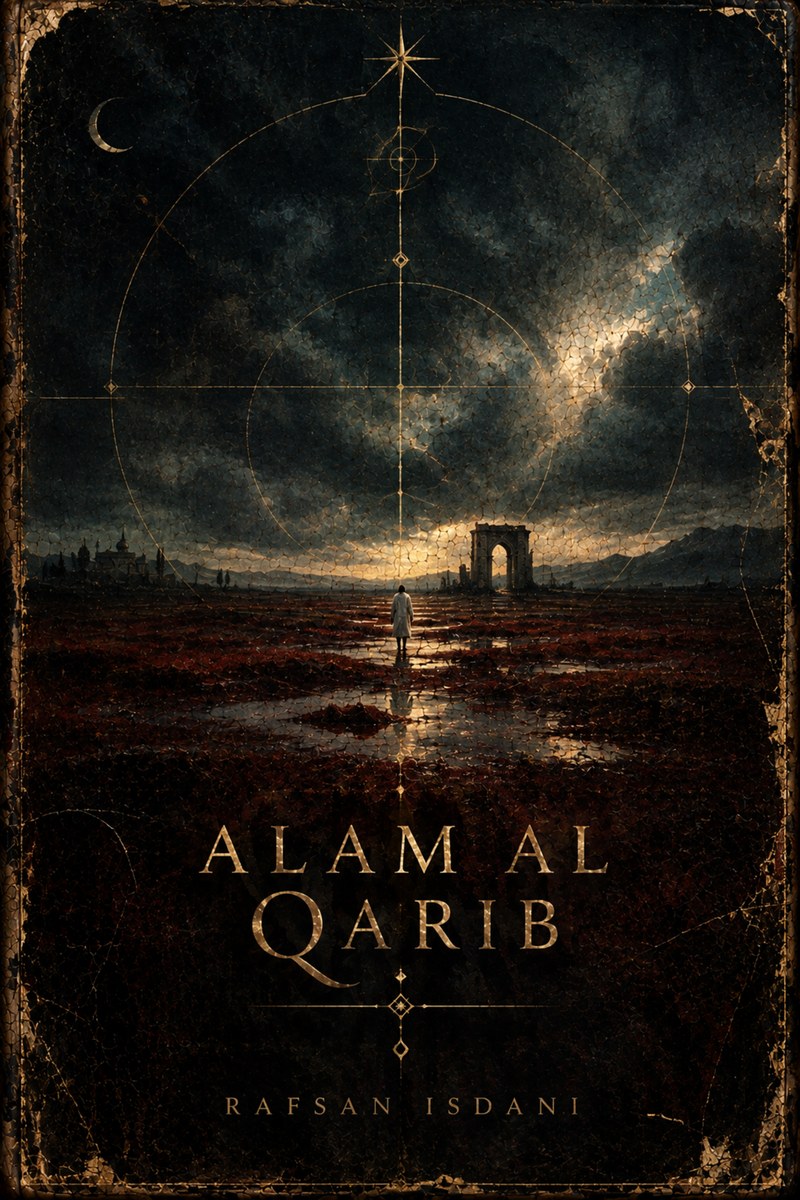
    Cover of Alam al Qarib by Rafsan Isdani

    No. 04 · Fourth Novel

    Alam al Qarib

    A literary occult mystery — Sahir's journey toward a world that lies closer than it seems, and the truths hidden just beyond its threshold.

    Literary Occult Mystery · Hardcover & Kindle · 2026

    Rafsan Isdani on Goodreads

    Follow for new releases, ratings, and reader questions.

    Goodreads Author Profile

    Hobbies

    Beyond Engineering

    What keeps me inspired outside the lab

    Cars & Automotive

    From my B.Tech in Automobile Engineering to weekend drives — cars have always been a passion. I love learning about performance tuning, vehicle dynamics, and automotive innovation.

    Outdoor Adventures

    Living in Michigan's Upper Peninsula means embracing the outdoors — hiking through snow-covered trails, exploring nature, and enjoying the rugged beauty of the Keweenaw.

    Photography

    Capturing engineering marvels, scenic landscapes, and everyday moments through my lens. Photography helps me see the world with an eye for detail and composition.

    Travel & Culture

    From Bangladesh to India to Michigan — living across cultures has given me a global perspective. I enjoy exploring new places and connecting with people from diverse backgrounds.

    Fitness

    Staying disciplined and physically active — a habit shaped by my time in BNCC. Regular workouts keep me sharp and focused both mentally and physically.

    Continuous Learning

    Always exploring new technologies, reading about automation trends, and staying ahead of the curve in the rapidly evolving world of industrial robotics and AI.

    Contact

    Get in Touch

    Interested in working together? Let's connect.